Justin doesn't need to look anymore
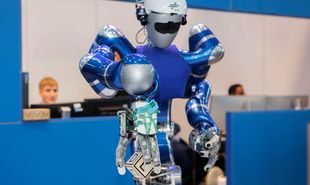
Whether it would sometimes be an improvement if a robot " grasped things the way a human would " is debatable. The German Aerospace Center ( DLR ), however, promotes this as an advantage for its humanoid " Agile Justin , " which can also " feel " with its robotic hands .
According to this, the humanoid robot can also turn things by hand in any desired direction without looking – which, although undesirable, is known to be extremely common among workers.
Agile Justin has sensors in its two four-fingered robotic hands: it "feel" objects. It recently demonstrated its capabilities at the automatica trade fair. Dexterity is considered a major challenge among robotics researchers. "Thanks to new methods of machine learning artificial intelligence, it has been possible for the first time to demonstrate abilities with the highly advanced mechatronics DLR hand that come close to human dexterity: In particular, blindly rotating and manipulating objects with a downward-facing hand was a challenge"says Professor Berthold Bäuml from the DLR Institute of Robotics and Mechatronics in Oberpfaffenhofen. Berthold Bäuml's AI research has been advancing the humanoid robot Justin for many years: Justin, for example, catches balls thrown to it or identifies materials by feeling them with its fingers. Now, self-learning AI has significantly expanded Justin's capabilities.
The researchers are using so-called "deep reinforcement learning"This means that Justin learns completely independently what is right and wrong. In this application, for example, the robot learns to recognize dexterity through the "Rotating the object towards the target is good" and "Dropping the object is bad"Machine learning of dexterity takes only two to three hours in a simulation. Then Justin masters the task. He develops his finger movement strategy much like a human, through trial and error. "The robot can then directly implement his solutions in the real environment. Even we as researchers are often surprised. The possibilities of our new learning AI methods are fascinating"says Bäuml.
In addition, another first in AI robotics has been achieved: Justin can grasp any object with his multi-fingered hand. Here, the researchers have solved two key problems using AI. From 50,000 examples, the robot has learned a so-called "foundational model" which allows him to infer the shape of the back from the visible front. Justin has thus acquired an understanding of 3D shapes. Secondly, Justin can find an optimal hand position and adjust his twelve finger joints accordingly. Humans grasp objects intuitively. To impart this intuition to the robot, another AI was trained with thousands of examples for tens of thousands of objects. "The calculation took several days. But now the robot can recall the correct grip within fractions of a second"explains Bäuml. At automatica, Justin already demonstrated his dexterity with objects handed to him by members of the audience.
 Photos: DLR
“Never before have robotic hands been able to manipulate such a wide variety of objects so quickly and precisely. This success was only possible through the combined use of cutting-edge AI methods with model-based methodological approaches and many years of robotics experience”says Professor Alin Albu-Schäffer, Director of the DLR Institute of Robotics and Mechatronics. “Until now, it was often assumed that a very large amount of data was needed to teach robotic hands skillful object handling. Unlike the data for Large Language Models, experimental data in robotics, even when generated through simulation, is very resource-intensive. The DLR research team has now found a way to require less data by leveraging more robotics expertise and a new learning architecture. This allows the team to train these models even on simple computers and eliminates the need for a large cluster. ”
The next major step in robotics could come in industrial manufacturing. Multi-fingered robotic hands could assemble highly complex and small parts if they mastered flexible, intelligent manipulation as standard. DLR researchers are working on this, for example, in the "SmartHand".
Bäuml's research group relies on deep learning as the core principle for building autonomous robots. By combining sensors and motor skills with learning AI, they aim to approximate human capabilities. The highly qualified staff of this young AI research group primarily come from the Technical University of Munich. Furthermore, they have research collaborations with renowned technology companies.
LI-NEWSLETTER
Every week, the latest logistics news from Switzerland, the EU and the rest of the world.
Subscribe now